
NOTE
3.5 Distributed Consistency Models
1. What Are Distributed Consistency Models - Different consistency models solve consistency problems to different degrees. 2. Categories of Distributed Consistency Models 2.1. Strong Consistency - C in CAP.md - Also called linearizability. 2.2. Weak Consistency - Eventual consistency - Causal consistency - Read-your-writes consistency - Session consistency - Monotonic-read consistency - Monotonic-write consistency - Prefix-read consistency
This is a historical learning note and may contain outdated or incomplete understanding.
1. What Are Distributed Consistency Models?
- Different consistency models solve consistency problems to different degrees.
2. Categories of Distributed Consistency Models
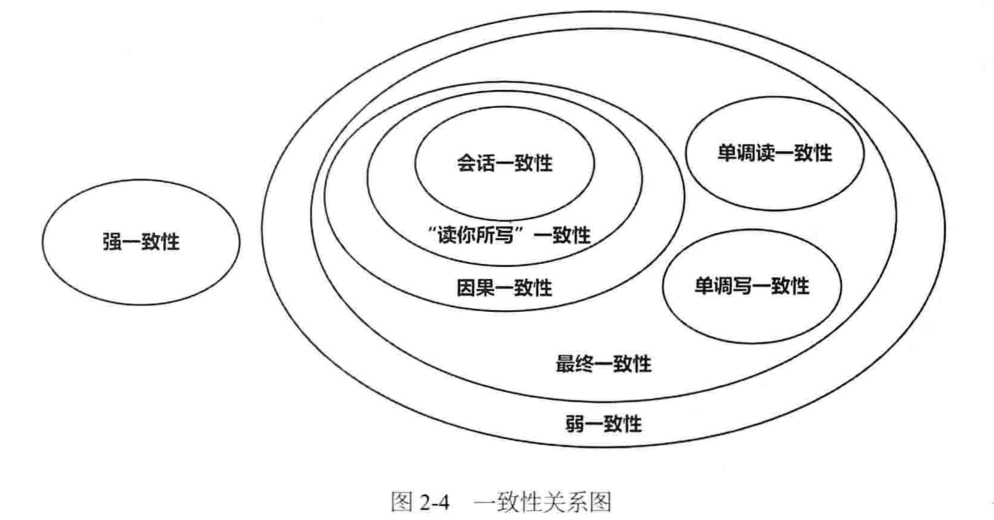
2.1. Strong Consistency
- C in CAP.md.
- Also called linearizability.
2.2. Weak Consistency
- Eventual consistency
- Causal consistency
- Read-your-writes consistency
- Session consistency
- Read-your-writes consistency
- Monotonic-read consistency
- Monotonic-write consistency
- Prefix-read consistency
- Causal consistency
3. Linearizability
3.1. What It Is
- Once one client successfully completes a write, all clients reading data from the database must be able to see the value that was just written.
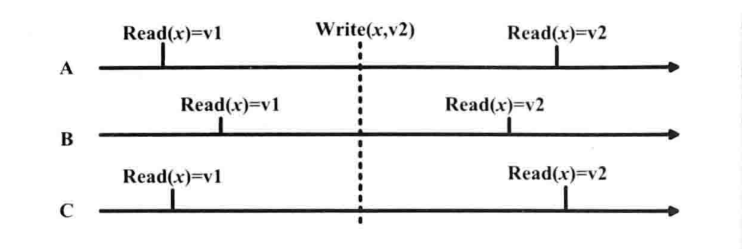
- If the storage satisfies linearizability, client processes can treat the storage as if:
- There is only one copy of the data.
- All operations are atomic.
3.2. Use Cases
- Distributed locks and Leader election: for example, Leader election is essentially that whoever acquires the lock becomes the Leader.
- Uniqueness guarantees: for example, usernames must be unique.
- Ordering across multiple channels: for example, RPC calls + message queues.
3.3. Implementation
- Single-Leader replication + consistency algorithm:
- The consistency algorithm solves split-brain and stale-read problems in single-Leader replication.
- Use synchronous rather than asynchronous replication.
3.4. Problem
- Linearizability sacrifices A in CAP.
4. Eventual Consistency
4.1. What It Is
- E in BASE.md.
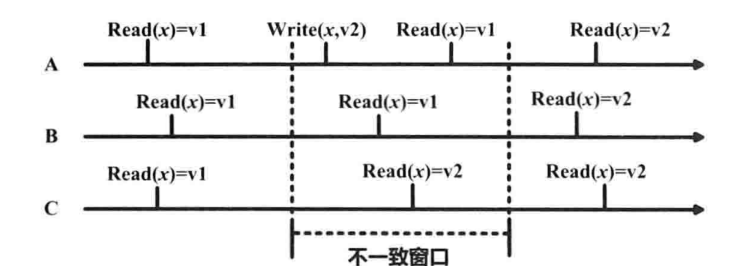
- Eventual consistency requires that once an update succeeds, data on each replica will eventually reach a completely consistent state, but the time required to reach that state cannot be guaranteed.
4.2. Problem
- There is no specified waiting time.
5. Causal Consistency
5.1. What It Is
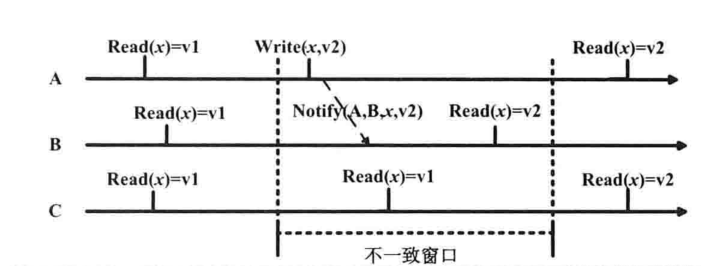
- If processes a and b have a causal relationship, after a is updated, process b needs to be notified.
5.1.1. Total Order and Partial Order
- A total order means that given two values a and b, we can always know either a > b or a < b.
- A partial order means that given two values a and b, it may be that a > b, a < b, or a and b cannot be compared.
5.1.2. Causality
- If a is the cause and b is the effect, then a happens before b, and b cannot happen before a.
- Causality is a partial-order relation.
- Linearizability is a total-order relation.
5.2. Implementation
- Causal-consistency sequence number + total-order broadcast.
5.2.1. Causal-Consistency Sequence Number
- It is an increasing ID used to establish a total order for all operations.
- Single Leader: it can be generated by the primary.
- Multiple Leaders: Lamport clock.
5.2.2. Total-Order Broadcast
- Used to determine when the total order takes effect.
- Through a single-Leader, multiple-Follower mechanism, all operations are ordered on the Leader node, which determines the overall operation order and broadcasts that order.
- It is a protocol for exchanging messages between distributed nodes, with two properties:
- Reliability: messages are not lost.
- Ordering: the order in which messages are sent is the order in which they are received.
5.2.3. Problems with Total-Order Broadcast
- If throughput exceeds the processing capacity of a single Leader, how should the system be scaled?
- If the Leader fails, how should failover be performed?
6. Read-Your-Writes Consistency
- A user has just written data to the Leader and can read it from the Leader, but if the user immediately reads from a Follower, the data may not yet be readable.
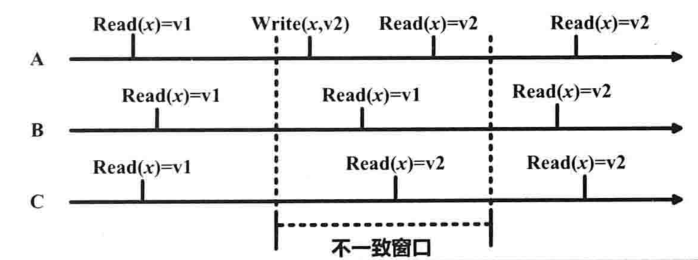
6.1. Implementation
- Read from the Leader
- Within one minute after an update, the user reads the data they wrote from the Leader node, and reads data written by other users from Follower nodes.
- Disadvantage: this only applies to scenarios where each user modifies only their own data.
- Timestamp mechanism
- The client records the logical time of its last write. When reading from a Follower, it must read data after that time; otherwise, route to another node or wait. The timestamp can be logical time or system time.
7. Session Consistency
7.1. What It Is
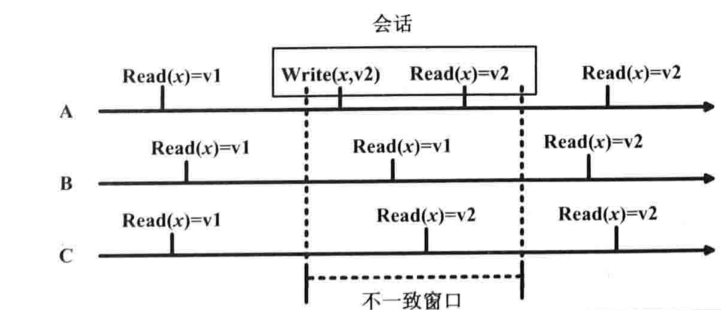
- Read-your-writes consistency can be guaranteed during a session.
8. Monotonic-Read Consistency
8.1. What It Is
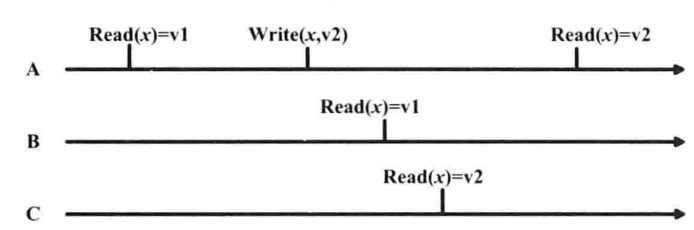
- The Leader has synchronized to follower1 but not to follower2:
- The user first reads from follower1 and gets the new data.
- Then the user reads from follower2 and the data disappears.
- Monotonic-read consistency guarantees that if a process reads version v2 of data x, all subsequent reads by that process cannot see a version older than v2, such as v1.
8.2. Implementation
- Route the same user to the same replica for reads through
hash(uid).
9. Monotonic-Write Consistency
9.1. What It Is
Monotonic-write consistency can guarantee serialization of a process’s multiple write operations. Without this guarantee, application development is difficult for developers.
10. Prefix-Read Consistency
10.1. What It Is
- User 1 writes data1 to leader1.
- User 2 writes data2 to leader2.
- leader2 synchronizes data2 to follower2.
- User 3 reads from follower1 and does not see data1.
- User 3 reads from follower2 and sees data2.
- leader1 synchronizes data1 to follower1.
- User 3 reads from follower1 and sees data1.
10.2. Implementation
- Ensure that all causally related writes are written to the same partition.
Discussion
Sign in with GitHub to comment. Discussions are stored as GitHub Issues.View on GitHub